Objectives

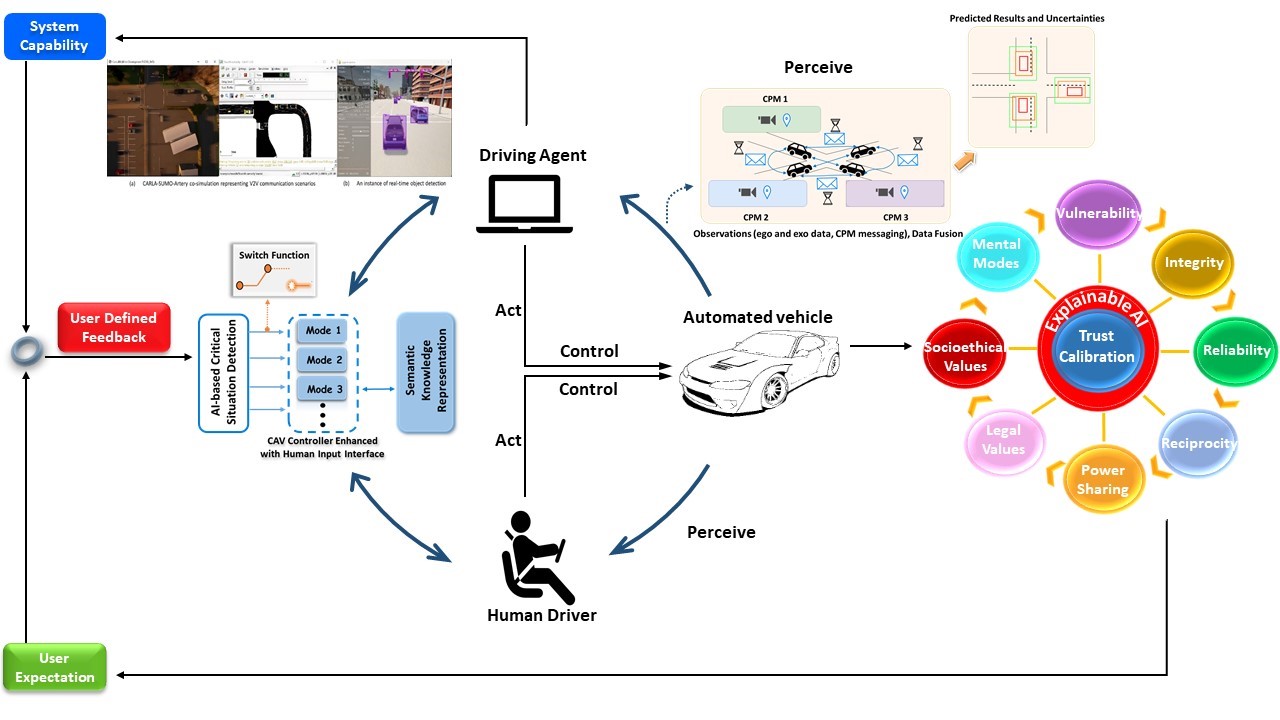
SO1: To establish a framework for Trust Calibration in Autonomous Driving.

SO2: To develop AI-based, Trust-Aware Decision Making and Control Policies leveraging the Collective Perception Service and ensuring Hybrid Intelligence.

SO3: To develop a Collective Perception Model based on multi perspective and multimodal sensor fusion which includes Object Detection and Tracking as well as Behavioural Modelling of the involved participants to generate predictions of the future state.

SO4: To develop reliable communications infrastructure to facilitate efficient CPM dissemination.

SO5: To ensure integrity and failsafe operation of the hybrid intelligent compliant system.

SO6: To develop demonstrators of the developed technology generating open data sets to be enriched with Generative AI methodologies.
Image

PI’s Welcome: Our project explores how Reconfigurable Intelligent Surfaces (RIS) can enhance Cooperative, Connected and Automated Mobility (CCAM), especially in challenging environments where reliable V2V and V2X communication is essential. By investigating the impact of RIS on cooperative driving and collective perception, we aim to advance autonomous mobility research and strengthen Frederick Research Center (FRC)’s capacity to lead future innovations. Thank you for joining us on this journey toward safer, smarter, and more connected transportation.

The AUTOMETA Research Project (BRIDGE2HORIZON/0823A/004) is funded by the European Regional Development Fund and the Republic of Cyprus through the Research and Innovation Foundation.

Useful Links
Contact Us
Dr. Chrysostomos Chrysostomou
Associate Professor
ch.chrysostomou@frederick.ac.cy 
7, Y. Frederickou Str., Pallouriotissa, Nicosia 1036, Cyprus
+357 22394360 - Ext 42114
Image
Image
Image

© 2024 - 2025, Frederick Research Center

All right reserved.