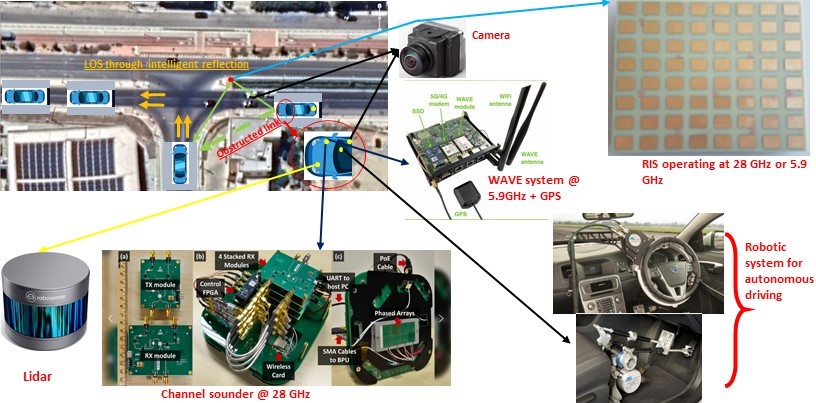
Cooperative, connected and automated mobility (CCAM) is a thriving sector with the promise to bring enormous improvements in road safety, traffic efficiency and comfort in driving with significant social, economic and environmental benefits. Connectivity can be greatly enhanced by modern communication technologies which can bring the 2ms delay bounds required by ever demanding real-time CCAM applications closer to reality. Reconfigurable Intelligent Metasurfaces (RIM) constitute such an emerging communications technology which has been heavily researched the last few years. However, the integration of RIM technologies in vehicular networking has been investigated merely from a communications perspective, leaving the effects on CCAM applications and automated driving performance largely unexplored. The project aims at addressing this gap in the field to consider cooperative driving and collective perception in the presence of RIMs. The well-established novelty of the proposed activities will promote scientific excellence and together with specific networking, coordination and support actions to be undertaken within the project will allow FRC to lead the effort towards the preparation of a relevant research proposal in the upcoming call for proposals in Pillar II of the Horizon Europe Work Programme.