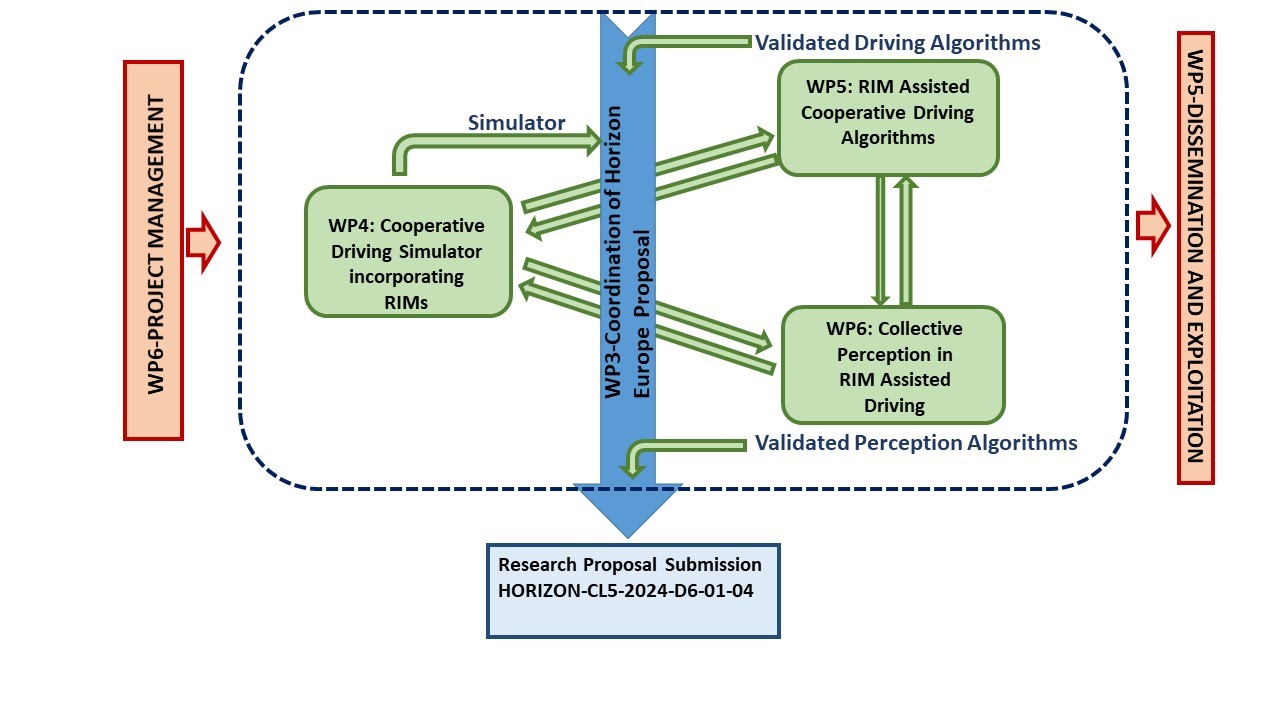
TO1: To develop a cooperative simulation framework, based on the PLEXE Simulation Platform, which incorporates models for RIM assisted communication channels and RIM functionalities (e.g. beam splitting).
TO2: To design, develop and evaluate novel cooperative, connected and automated driving (CAD) algorithms realizing specific maneuvers. The algorithms will be adaptive in nature, considering the RIM assisted communication channel for sensor data exchange.
TO3: To investigate real time, AI based object detection algorithms for collective perception when vehicles and roadside infrastructure share detection information from their live stream about surrounding objects via RIM assisted communication channels, thereby enhancing autonomous driving capabilities and cooperative perception. The tradeoff between detection accuracy and latency will be investigated and enhancements to the detection algorithms will be proposed to improve the performance limitations to be identified.
TO4: To improve the research capacity of FRC, through staff engagement on a state-of-the-art topic with established novelty, relevant to the topic of an upcoming call in Pillar 2 of the Horizon Europe Program. Metasurface Assisted Autonomous Driving and Collective Perception will be investigated, which is relevant to the call “AI for advanced and collective perception and decision making for CCAM applications (CCAM Partnership)” HORIZON-CL5-2024-D6-01-04, in Cluster 5: Climate, Energy and Mobility of the Horizon Europe Program.
TO5: To implement Support and Coordination Actions to leverage the knowhow gained from the proposed research activities for the preparation of a Research Proposal in Pillar II of the Horizon Europe Program. Although various upcoming calls for proposals will be considered during the project activities a specific call is targeted at this stage: “AI for advanced and collective perception and decision making for CCAM applications (CCAM Partnership)” HORIZON-CL5-2024-D6-01-04, in Cluster 5: Climate, Energy and Mobility of the Horizon Europe Program.